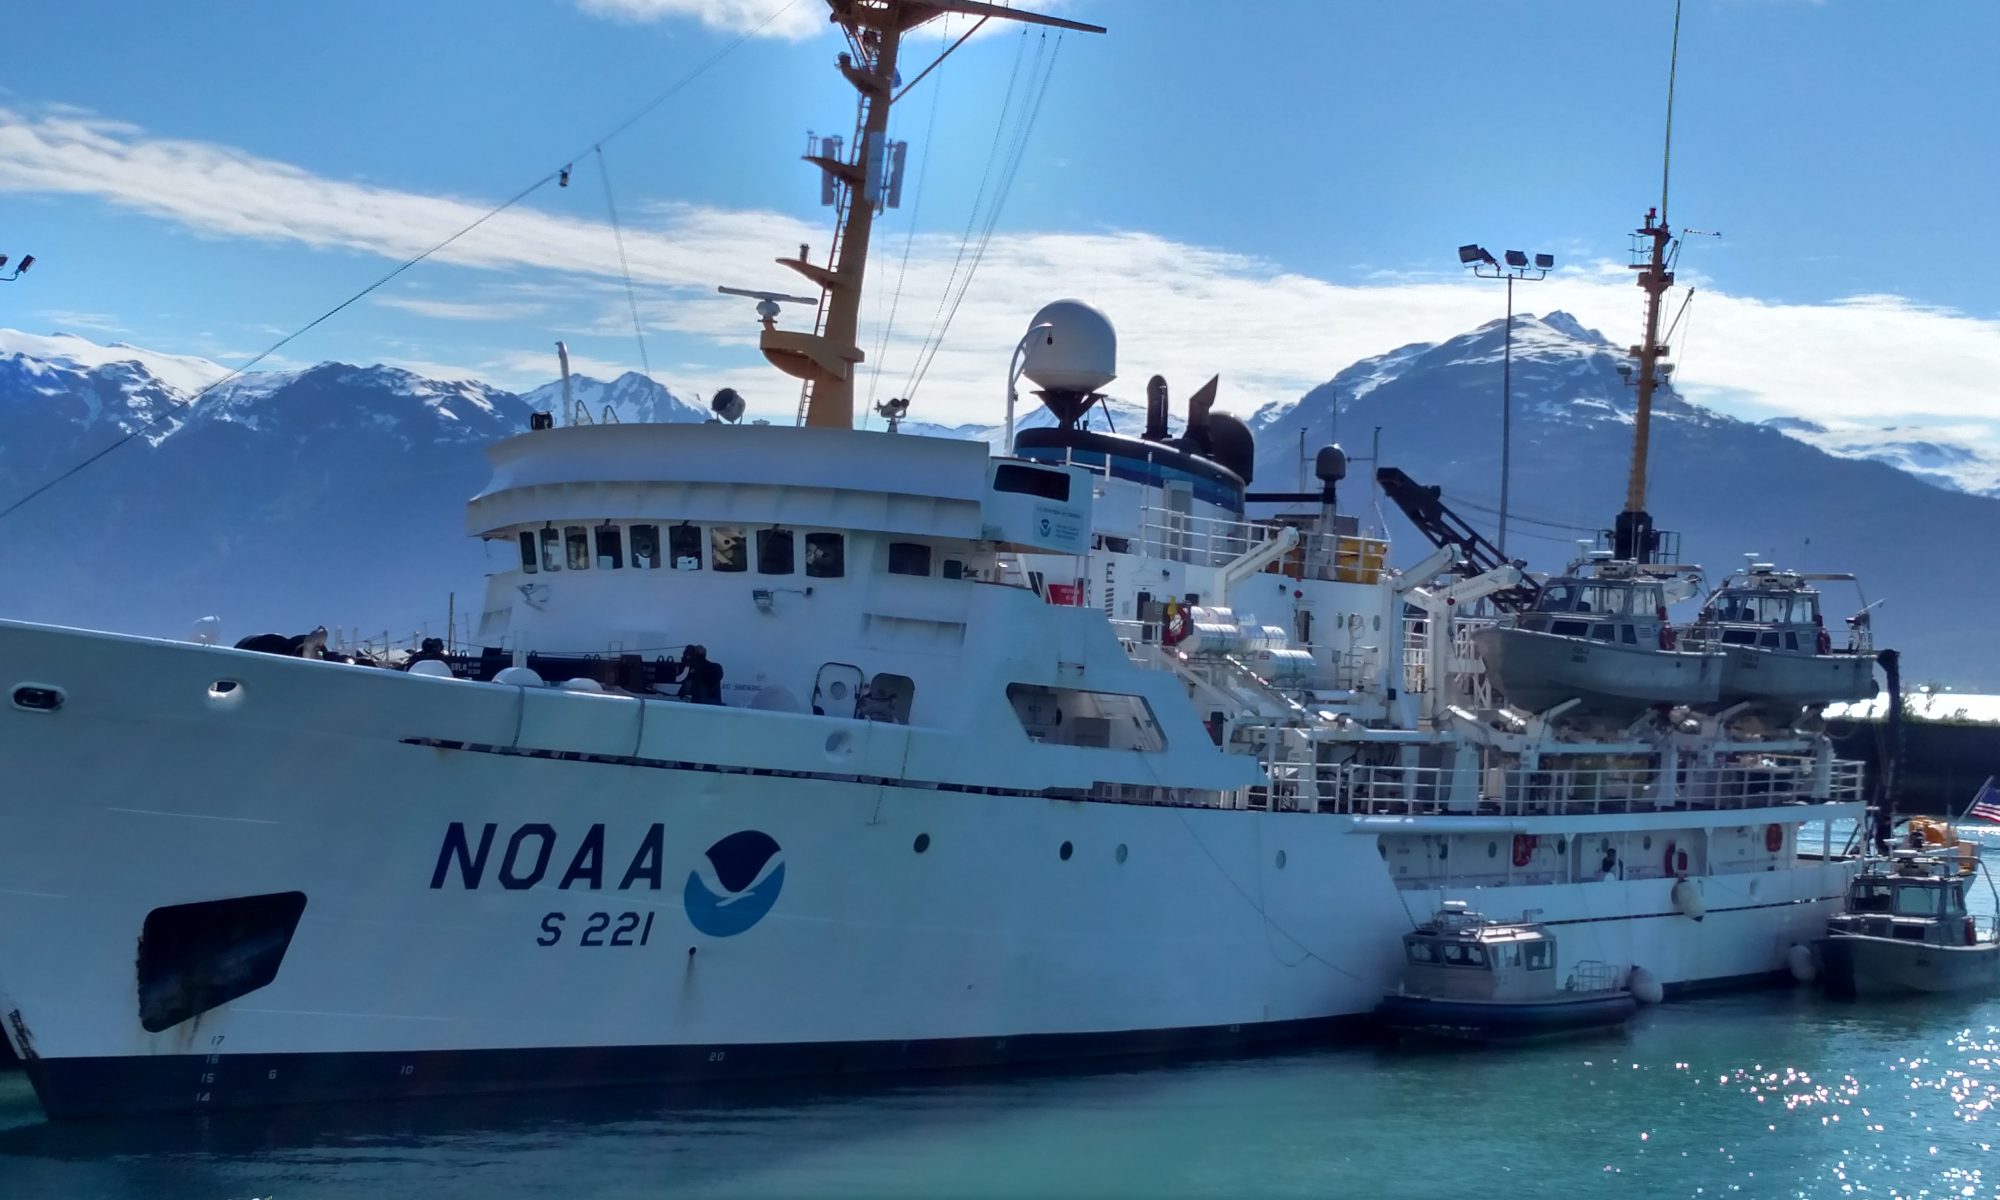
Kathy Virdin, July 24, 2004

NOAA Teacher at Sea
Kathy Virdin
Onboard NOAA Ship Rainier

July 20 – 28, 2004

Mission: Hydrographic Survey
Geographical Area:
Eastern Aleutian Islands, Alaska
Date:
July 24, 2004

Latitude: 55 degrees 17.194 N.
Longitude: 160 degrees 32.23 W.
Visibility: 3 nautical miles
Wind direction: 100 degrees
Wind speed: 10 kts.
Sea wave height: 1-2 ft.
Swell wave height: 2-3 ft.
Sea water temperature: 10 degrees C.
Sea level pressure: 1002.0
Cloud cover: Cloudy with rain

Science and Technology Log

Today we went out on a launch (my first in the Shumagin Islands). We traveled near the area of Simeon Bight to run lines to check depth measurement. An example of why this is so important is that in one of their launches, they found after an earthquake, a 30 meter drop-off near a fault line. This wasn’t on any charts because it had been caused by the earthquake itself. Before they begin the depth measurements, it’s vital that they take a cast with the salinity, pressure and temperature instrument. This information is then hooked directly into the computer to be calculated into the depth findings, so that the depth can be corrected by these factors. We ran cross lines (lines that cris-crossed each other) as a quality check to be sure that no area had been missed. The transducer (which sends out a multi-beam swath of sound) is lowered into the water by a mechanical arm. This is high-tech stuff! The computers are also recording the GPS (global position system) location of our boat at all times. When we learn the depths of the waters we pass over, we have to know exactly where we are in order to record this on nautical charts. Out of 24 satellites, we need at least 5-7 within range plotting our location to ensure accuracy. The computers divide the screen into sections which show our depth reading, a picture of the ocean floor by sonar calculations and the range our instruments will accurately reflect. We have traveled a range of 88 meters in depth to 6.7 meters in depth. Interestingly, one possible technology that is being tested and may be the best method of the future is called Lidar, which means sonar transmitted from an airplane, which flies over coastal areas and can give a depth reading on land and in the ocean. The RAINIER is testing one area that has been measured by Lidar to compare our measurements with theirs to check their accuracy. This would be a safer method, since lowering the launch boats and retrieving them has a certain amount of risk.

We’ve just seen some lazy puffins that are swimming on top of the water, which makes them look like sitting ducks. As we return to the RAINIER in the late afternoon, we bring back a lot of data that the survey technicians will assess and correct to be submitted to the cartographers.

Personal Log

We had a rainy, foggy afternoon on the water while we were surveying, with clouds that hovered over the green, craggy cliffs. It makes a beautiful sight. We felt we got a lot accomplished and returned with some good data. In talking with various members of the crew, I’ve gotten some good ideas to use in my lesson plans as they help me think of ways to explain their operations that will simplify it, such as flashlights taped together to represent a multi-beam sonar swath. I’m going to catch up tonight on correspondence, and refine my lesson plan ideas tomorrow. I can’t wait to take all these ideas back to the classroom!

Kathy Virdin, July 23, 2004

NOAA Teacher at Sea
Kathy Virdin
Onboard NOAA Ship Rainier

July 20 – 28, 2004

Mission: Hydrographic Survey
Geographical Area:
Eastern Aleutian Islands, Alaska
Date:
July 23, 2004

Latitude:55 degrees 43.34’N
Longitude: 159 degrees 10.967’ W
Visibility: 10 nautical miles
Wind direction: 175 degrees
Wind speed: 8 kts.
Sea wave height: 0-1 ft.
Swell wave height: 0-1 ft.
Sea water temperature: 11.7 C.
Sea level pressure: 1016.2 mb.
Cloud cover: Cloudy

Science and Technology Log

Today we have been in transit to the Shumagin Islands. Two launches were sent out to do Reson (shallow to mid-depth) measurements and one launch did the Elac (mid-depth to deep waters). This area really needs accurate depth measurement, since it’s an area where fishermen come frequently. The information that is received and processed on board the RAINIER is then sent to the Nautical Data Branch of NOAA where it is interpreted and made into the hydrographic sheets with added interpretative data. Then it next goes to a production team who apply it to charts. The next step for the information is to go to the Update Service branch which combines all data and puts it in the final form of nautical charts that is used by the Navy, cargo ships, tanker ships and all mariners (such as fishermen). So the RAINIER plays a vital role in getting critical information to those who use it daily to ensure their safety.

I was able to catch several of the crew for an interview. I interviewed Megan Palmer, who is a survey technician. To prepare for her job, Megan received a degree in geography and received additional training in computer systems, including the complex GIS system. She explained that NOAA is moving toward electronic nautical charts that will allow you to set your scale close or far away on the computer, depending on what you need. Alarms will go off if you get into shallow water. However, there will always be a need for nautical charts and that’s where NOAA excels. Megan enjoys her job as it gives her the opportunity to see Alaska while being on the water, and the chance to look for the unexpected in surveys. Often, she is part of the team that is charting waters that have very few depth soundings. She also enjoys the fact that NOAA tests software to see how well it works and then make recommendations to companies to improve features that the survey technicians need. She notes that there is definitely a need for more survey technicians and that it’s a rewarding and exciting career for any student who loves the ocean and wants to travel.

Personal Log

Today we had the thrill of seeing a whale swimming in the distance while we all tried to take a picture (very difficult since it moves in the water so quickly). We dropped anchor tonight in the Shumagin Is. We’ll stay here several days while the survey launches run lines in different areas. We’ve entered into an area of heavy fog and it was neat to hear the fog horn being sounded every few minutes as we move through the water. I enjoyed looking a computer file of pictures that show all the places the RAINIER has been in Alaska. Beautiful scenery!

Kathy Virdin, July 20, 2004

NOAA Teacher at Sea
Kathy Virdin
Onboard NOAA Ship Rainier

July 20 – 28, 2004

Mission: Hydrographic Survey
Geographical Area:
Eastern Aleutian Islands, Alaska
Date:
July 20, 2004

Time: 2:20 p.m.
Latitude: 55 degrees 39.4 N
Longitude: 158 degrees 00.3 W
Visibility: 10 nautical miles (nm)
Wind direction: Northwest
Wind speed: 7 kts
Sea wave height: 0-1 ft.
Swell wave height:2-3 ft.
Sea water temperature:13.3 degrees Celsius
Sea level pressure:1010.1mb.
Cloud cover:3/8 partly cloudy

Science and Technology Log

Today we reached the point where we would begin our surveys. I watched the survey technicians lower a Seabird (sound velocity profile unit) into the water, then raise it back up and hook it into a computer, where they could download the information. This will give them the salinity (salt content), temperature and pressure of the water. They lowered the Seabird 117 meters down into the water, before retrieval. At the same time, from the hull of the ship, a transducer sound wave emitter is sending sound waves to the bottom and measuring the time it takes for their return. From this information, they will calculate the distance to the floor of the ocean. They use this data from the Seabird to help them make corrections in the sound wave speeds from the transducer. The salinity, temperature and pressure will cause variations in the speed of sound, so they need to correct for this effect to gain an accurate depth measurement.

This information is being processed and viewed by cartographers (map designers) who will take what data the RAINIER gives them to update old maps or develop new maps and charts. These maps are used by fishermen, geologists or anyone who navigates through these Alaskan waters. We are headed for the Shumagin Islands where we will send out launches (smaller boats) to measure depths in places where the Rainier might not otherwise go. I found it interesting to note that environmentalists would also use this information, since they know where certain species of fish are likely to live, and they can decide how best to protect them if they are endangered. We will go back and forth three times in one plotted line to make sure our data is accurate and complete. When we send out a launch in more shallow water, they will use a different sonar device, called a Reson. It emits higher sound waves which will give a more accurate reading. For middle to deep depth measurement, they will use the Elac sonar and a vertical beam echo sounder which goes straight down that can be used for shoreline measurements. Because Alaska has such rough terrain, it’s important to get accurate measurements for those who use her waters.

Personal Log

I am amazed by how specific the data is that the survey technicians collect and how well everyone knows their job. This is truly a finely tuned, professional organization. Everyone has been so kind to answer my many questions even though I’m sure I’ve gotten in their way. I’ve spent a lot of time in the Plot room, where the data is logged into the computers and then interpreted by the technicians. Outside, it’s a beautiful, sunny day, which is the first pretty weather we’ve had. We saw a pod of whales, recognizable by the blow of water coming from their nostrils. I could see them really well through the high-powered binoculars that belong to the ship. I am working on a list of questions that I will use to interview different members of the crew, as well as the scientists so I can take this information back to my students, as they learn what the roles are on a NOAA vessel. Someday, I want my students to be the next generation of scientists that use the knowledge we are gaining today to frame the discoveries they will make in the future.

Sena Norton, July 13, 2004

NOAA Teacher at Sea
Sena Norton
Onboard NOAA Ship Rainier

July 6 – 15, 2004

Mission: Hydrographic Survey
Geographical Area:
Eastern Aleutian Islands, Alaska
Date:
July 13, 2004

Location: At anchor, Popof Strait, Shumagin Is. AK
Latitude: 55 deg 17.9’ N
Longitude: 160 deg 32.13’W
Visibility: 1nm
Direction: 116 deg
Wind Speed: 10 kts
Sea wave height: n/a
Swell wave height: 0-1 ft
Seawater temperature: 10.1 deg C
Sea level pressure: 1011.0 mb
Cloud Cover: 8/8 Fog
Weather: Foggy with drizzle and areas of rain 12.1 deg C (air temp)

Plan of the Day:
Four launches for shoreline verification and continuation of hydro in deeper water.

Science and Technology Log

I learned the process and background concerning shoreline verification. This process ties in nicely with my new understanding of the process of Laser Airborne Bathymetry and how the two connect together. Shoreline verification is a process where a launch surveys to the 4-meter line and in the process correctly locates any targets found close to shore. The launch actually touches the target, at times from multiple sides so that a true GPS tag can be attached to the feature. This process helps the survey crew make better sense of wide swath readings and discern between sonar “fluff” and true features. Sometimes kelp or other objects block the sonar from capturing an accurate image and in the case of larger objects they are required to be “eye ball” verified for all survey areas. Shoreline is also used to double check location of known targets for drift or geologic movement. In the case of these Alaskan waters, the bottom changes yearly and the same can be said for the shoreline. Rocks move, and sand drifts cause sediment build-ups in different areas and underwater features might not have been placed accurately on the chart in the first place. All these factors add in to the need for physical shoreline verification of the survey swaths.

The jet boat launches are able to go almost all the way into shore but are not used until a prop motor launch has already done a through evaluation of the grid. According to the coxswains, shoreline is one of the more nerve-racking operations that they conduct. They are in shallow water trying to find hazards to navigation and they are still asked to safely navigate themselves. At times they are going into pockets almost blind because of the initial survey information being a tad sketchy. After of day of shoreline the coxswain is mentally and physically worn out.

Personal Log

Last night was a fun night on board, a group of crew and corps officers played some board games and let off some steam. This really is a fun crew to be around they are ready to have a good time and I believe they genuinely enjoy each other’s company. (Even if at times I know they drive each other crazy!) I am feeling more a part of the ship now as ever before, everyone is a friendly face and people are interested in what I am doing and what I do on dry land. They are very supportive of teachers and education and that is a boost to my morale because I feel supported in what I am doing here.

I have also enjoyed the time made available by being on board to work with the other TAS and collaborate with lesson ideas and simply “talk” to each other. Many times the one thing that teachers starve for is a chance to really get down and work with their colleagues. We are already planning on linking our classrooms, like Sister Classes for projects, pen pal and even to track the weather on opposite sides of the U.S. An added benefit is that she also just finished her first year of teaching and teaches at the same middle school level and I do. We have our careers in common and seem to have similar ideas on the direction of science education and its benefit to our students. We have completely different experiences as an educator because I teach in public school and she teaches in a small private school, but hearing the experience of the other has put a perspective not only on education but also on my professional/personal goals for the future of my career.

Question of the Day:
What is a “gyro” and why is it used on a ship?

A “gyro” or gyroscopic compass is the ships compass that is always pointed at the North/South axis no matter what the ship is doing in the water. It can be compared to a child’s top in the way that it works. It is important for a ships compass to be oriented in the N/S axis to accurately navigate and find the exact lat/long point. A compass will always point toward magnetic North which is about 1,600 km south of the North Pole (where all the meridians of longitude converge).

Sena Norton, July 11, 2004

NOAA Teacher at Sea
Sena Norton
Onboard NOAA Ship Rainier

July 6 – 15, 2004

Mission: Hydrographic Survey
Geographical Area:
Eastern Aleutian Islands, Alaska
Date:
July 11, 2004

Location: At anchor Popof Strait, Shumagin Islands, AK
Latitude: 55 deg 17.30’ N
Longitude: 160 deg 32.14’ W
Visibility: 5 nm

15:00

Direction: 110 deg
Wind Speed: 10 kts
Sea wave height: 0-1 ft
Swell wave height: n/a
Seawater temperature: 10.0 deg C
Sea level pressure: 1018.2 mb
Cloud Cover: 5/8
Weather: Fair to Partly cloudy, spots of fog dissipating. 12.12 deg C

Plan of the Day:
Continue the launch survey with 2 boats. In house data cleaning and processing. Meeting with LIDAR tech stationed in Sandpoint.

Science and Technology Log

I personally spoke with a survey technician, Amanda McKinney on board to gather more information on hydrography and the process behind it. There were two main topics that we discussed: Application and history of marine survey, and the math/science behind the techniques.

Application/History

The technology used for marine survey has been improving by leaps and bounds and we are currently using a collection of old and new technology to gather data. Many nautical charts have not been charted for almost 80 years or more and some areas have never been accurately charted at all. The old process was to drag a lead line behind a transiting ship. This process was full of errors because you could never accurately know your depth, even if the length of the line was known; it was drug and therefore skewed the data. Very often a charted depth from these old processes are found to be dangerous wrong. Another mode of survey is the wire drag, where multiple ships drag a wire through the water column. Once a target has been hit, the depth of that underwater target is calculated, but never truly charted accurately. Side scan sonar came around and improved the survey capability, but it too has its drawbacks. Because the “fish” is towed there are many more mathematical corrections that must be made in order to get a reading that is close to the actual target. It does produce wonderfully clear pictures of what is around the “fish” but those images lack depth of field and the sonar cannot read directly below the transmitter. Quite often with side scan images, divers are needed to dive the sight of a possible target to get accurate readings. Multi-beam sonar can be used in conjunction with side scan to better improve the over all picture of the underwater area. Because multi-beam is able to give more accurate readings and the data is complied in 3-D images, surveyors can have both a clear image and precise depth reading all together. It is hoped in the future that there will be new sonar systems that can scan at 480 beams over .25 x .25 deg per beam with 40+ pings per second. The highest level of technology currently used by NOAA is the Reson 8125 (this system is attached to two boats currently) and it sends out 240 beams over 0.5 x 1 deg / beam at 15 pings per second and runs with 455kHz. Remember, that a short pulse (wavelength) will give better vertical resolution and higher frequencies give shorter pulses or wavelengths.

The math required to figure the depth is not very difficult, however in the case of the ocean, the computers must adjust all readings for depth, salinity, temperature and density, which in a way makes the math more difficult if done by hand.

Depth=Speed+ Time/2

Personal Log

I was able to spend some time with the survey tech’s today and got through some of the PowerPoint presentations that are available here on the intranet to educate myself more on the technology and process. I was pleased to see that I can apply some of the simple ideas to my classroom. When I teach certain science skills I will have real life data sets and examples for the kids to analyze. I also hope to get some of the kids excited in the field of sonar and survey, much needs to be done to improve the accuracy and reliability of these systems and the product they produce.

Sunday equals fishing off the fantail in between shifts. We have a resident pack of gulls that have found it much to their benefit to hang out for the halibut leftovers that get tossed overboard or that slip from bait hooks.

I found a whale bone yesterday on Egg Island and had the boat shop guys saw it in half so that both of us TAS’s could bring something back for the classroom. It is not a large chunk, but authentic to say the least. I also gathered some sea sponge that had washed up and a very unique white rock.

I was very surprised to see the people working on a Sunday. No one should ever question the dedication of the folks on board or say that this is an easy job. One of the engineers has not had a day off in two months or more. The ship is something that has to be tended too by her crew and command 24 hours a day 7 days a week. Self-sufficiency comes with some responsibilities!

Question of the Day

Which is better: side scan or multi-beam sonar?

There is not one that is better than the other so much as they can compliment each other to produce and more detailed and accurate product, namely the nautical charts and other products that use the information gathered via the sonar medium.