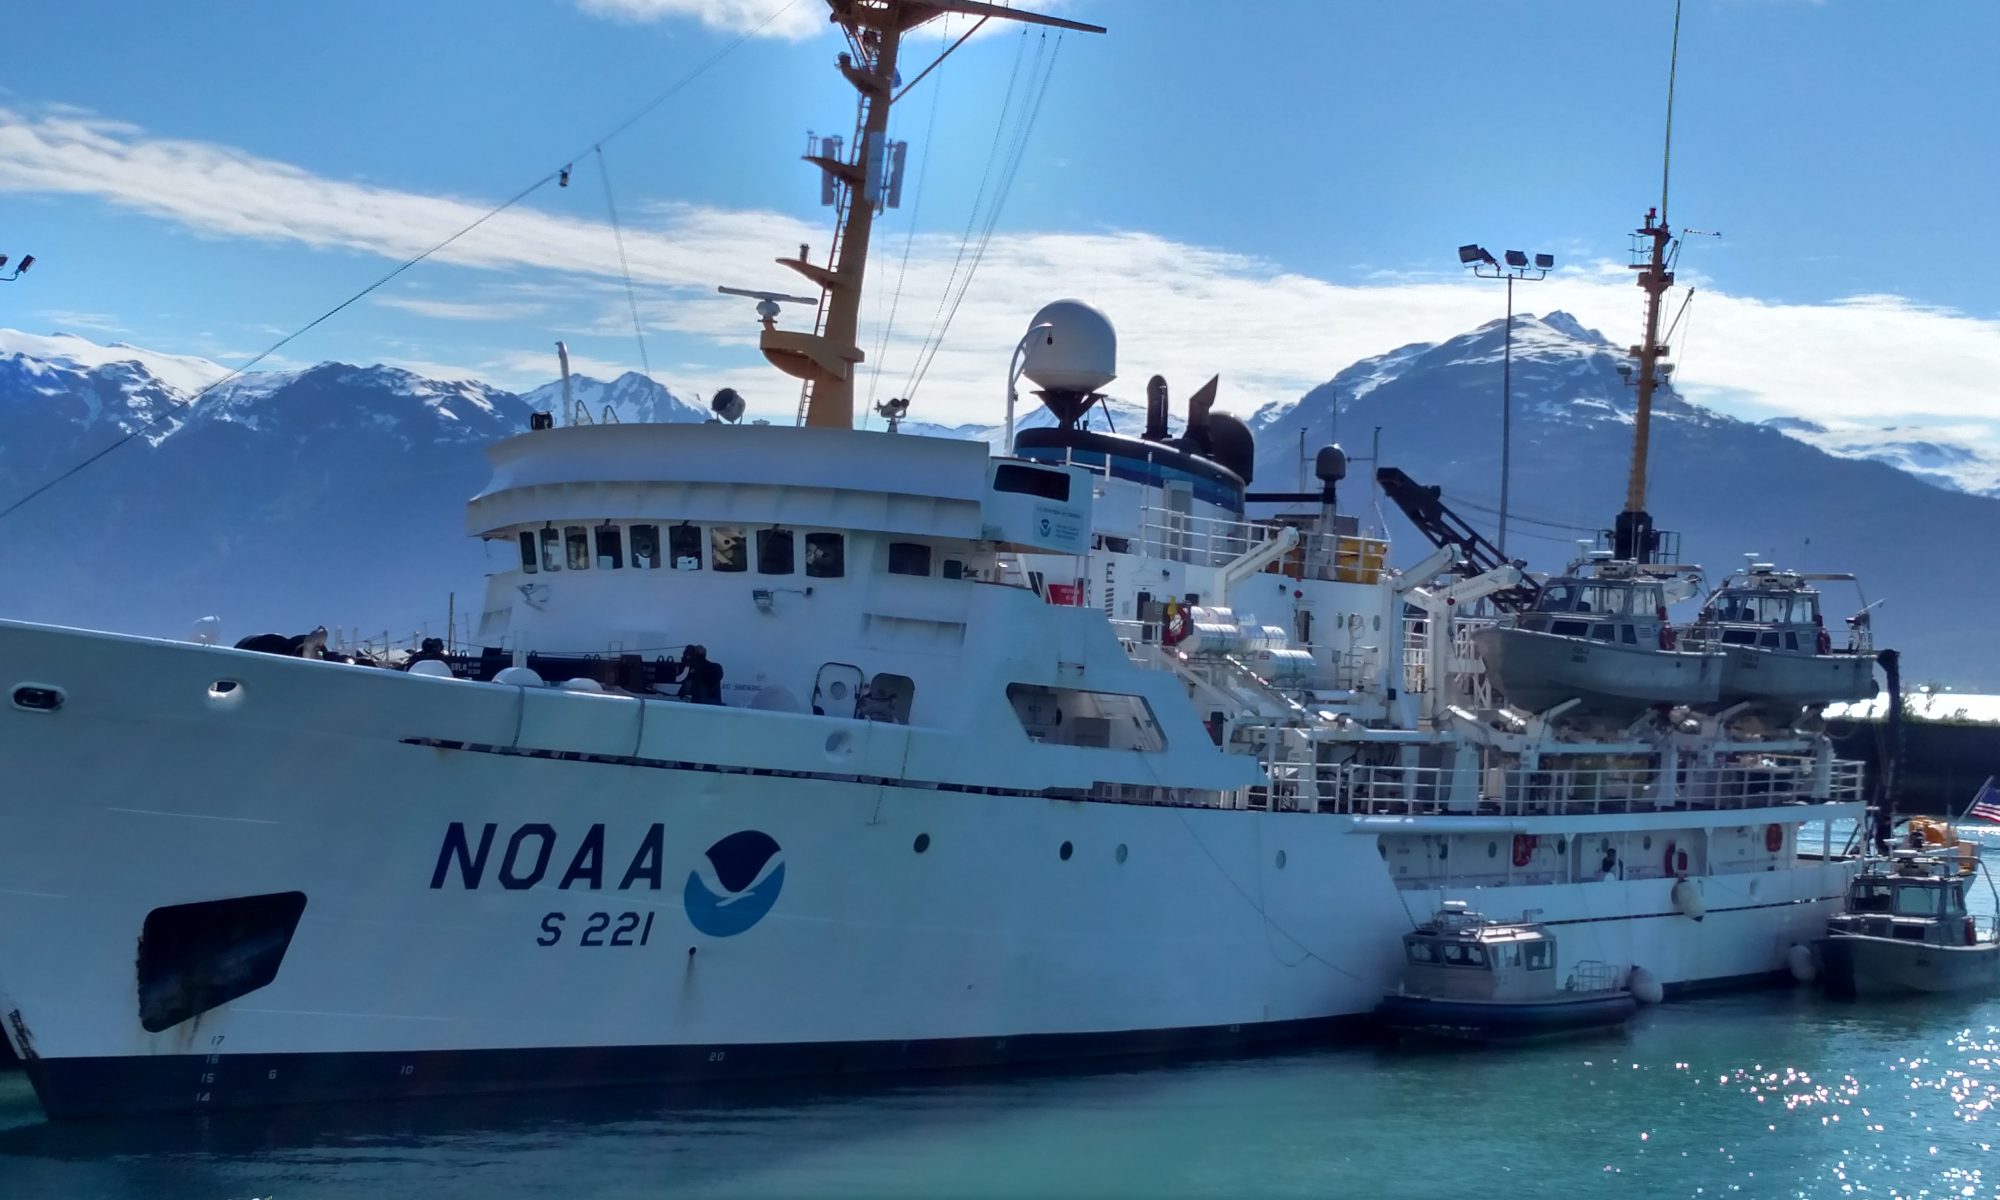
Kathy Virdin, July 24, 2004

NOAA Teacher at Sea
Kathy Virdin
Onboard NOAA Ship Rainier

July 20 – 28, 2004

Mission: Hydrographic Survey
Geographical Area:
Eastern Aleutian Islands, Alaska
Date:
July 24, 2004

Latitude: 55 degrees 17.194 N.
Longitude: 160 degrees 32.23 W.
Visibility: 3 nautical miles
Wind direction: 100 degrees
Wind speed: 10 kts.
Sea wave height: 1-2 ft.
Swell wave height: 2-3 ft.
Sea water temperature: 10 degrees C.
Sea level pressure: 1002.0
Cloud cover: Cloudy with rain

Science and Technology Log

Today we went out on a launch (my first in the Shumagin Islands). We traveled near the area of Simeon Bight to run lines to check depth measurement. An example of why this is so important is that in one of their launches, they found after an earthquake, a 30 meter drop-off near a fault line. This wasn’t on any charts because it had been caused by the earthquake itself. Before they begin the depth measurements, it’s vital that they take a cast with the salinity, pressure and temperature instrument. This information is then hooked directly into the computer to be calculated into the depth findings, so that the depth can be corrected by these factors. We ran cross lines (lines that cris-crossed each other) as a quality check to be sure that no area had been missed. The transducer (which sends out a multi-beam swath of sound) is lowered into the water by a mechanical arm. This is high-tech stuff! The computers are also recording the GPS (global position system) location of our boat at all times. When we learn the depths of the waters we pass over, we have to know exactly where we are in order to record this on nautical charts. Out of 24 satellites, we need at least 5-7 within range plotting our location to ensure accuracy. The computers divide the screen into sections which show our depth reading, a picture of the ocean floor by sonar calculations and the range our instruments will accurately reflect. We have traveled a range of 88 meters in depth to 6.7 meters in depth. Interestingly, one possible technology that is being tested and may be the best method of the future is called Lidar, which means sonar transmitted from an airplane, which flies over coastal areas and can give a depth reading on land and in the ocean. The RAINIER is testing one area that has been measured by Lidar to compare our measurements with theirs to check their accuracy. This would be a safer method, since lowering the launch boats and retrieving them has a certain amount of risk.

We’ve just seen some lazy puffins that are swimming on top of the water, which makes them look like sitting ducks. As we return to the RAINIER in the late afternoon, we bring back a lot of data that the survey technicians will assess and correct to be submitted to the cartographers.

Personal Log

We had a rainy, foggy afternoon on the water while we were surveying, with clouds that hovered over the green, craggy cliffs. It makes a beautiful sight. We felt we got a lot accomplished and returned with some good data. In talking with various members of the crew, I’ve gotten some good ideas to use in my lesson plans as they help me think of ways to explain their operations that will simplify it, such as flashlights taped together to represent a multi-beam sonar swath. I’m going to catch up tonight on correspondence, and refine my lesson plan ideas tomorrow. I can’t wait to take all these ideas back to the classroom!

Leyf Peirce, July 14, 2004

NOAA Teacher at Sea
Leyf Peirce
Onboard NOAA Ship Rainier

July 6 – 15, 2004

Mission: Hydrographic Survey
Geographical Area:
Eastern Aleutian Islands, Alaska
Date:
July 14, 2004

Time: 10:00
Latitude: N 55°17.24
Longitude: W 160°32.17
Visibility: 6 nm

Wind direction: 060
Wind speed: 1 knots
Sea wave height: 0 – 1 foot
Swell wave height: —
Sea water temperature: 10.0 °C
Sea level pressure: 1009.3 mb
Air temperature: 11.7 °C
Cloud cover: 7/8

Science and Technology Log

This morning I went out on launch boat 1 to conduct shoreline hydrography. Shoreline research differs very much from the other research I have seen so far, for it does not require “mowing the lawn” lines. Instead, it is a technique that is used to check the data collected from the LIDAR (airplane) labs. As I learned earlier this week, the data collected using a laser from the airplane primarily focuses on the shoreline and depths up to 30 meters. Today, we went along the shoreline checking questionable data points such as rocks and shoals that may have been confused with kelp or other variances in data collection. In order to do this checking, the survey technicians and officers conducting the research look at the LIDAR chart the day before launching and determine where rocks might be misplaced or not including at all. During surveying, which is what we did today, the researchers take a boat with a single beam echo sounding system and go to the places of concern. With some one on the bow to look out for uncharted rocks, the captain then drives over the areas where there might or might not be a rock. Because all of this is done very close to shore, it is very important to drive slowly. There is also a lot of kelp that can get in the way. Once the boat has past over the area a few times, the true depth is recorded as well as the position and a note is made on the chart where any changes need to be made to the chart. A relatively simple procedure, this type of shoreline research is critical for anyone planning to go on shore on any of these islands. Once again I was able to see how important this work is!

Personal Log

My morning was spent on the launch boat doing shoreline surveying. While the technology used was fascinating, I still did not hesitate to wonder at the naturally beauty of these islands. Almost completely uninhabited, these islands host wildflowers, puffin, gulls, and an occasional seal basking on a sandy or rocky beach. The green slopes are sharply cut by dramatic cliffs, creating a feeling of comfort and adventure at the same time. With the clouds dancing across these islands, I almost felt like I was about to see a dinosaur emerge from one of the cliffs—this looks very much like Hollywood’s rendition of “Jurassic Park”! This afternoon I plan on working on more lesson plans as well as a possible journey on another shoreline survey boat.

Sena Norton, July 14, 2004

NOAA Teacher at Sea
Sena Norton
Onboard NOAA Ship Rainier

July 6 – 15, 2004

Mission: Hydrographic Survey
Geographical Area:
Eastern Aleutian Islands, Alaska
Date:
July 14, 2004

Location: At anchor, Popof Strait, Shumagin Islands, AK
Latitude: 55 deg 17.24’ N
Longitude: 160 deg 32.17’ N
Visibility: 6 nm
Direction: 060
Wind Speed: 6 kts
Sea wave height: 1 ft
Swell wave height: n/a
Seawater temperature: 10.0 deg C
Sea level pressure: 1009.3 mb
Cloud Cover: 8/8
Weather: Temp: 12.2 deg C, showers, some fog in higher elevations

Plan of Day:
Five launches out for shoreline, multi-beam and visitors tour. I was on RA 1 for shoreline verification and LIDAR disproval.

Science and Technology Log

RA 1 is a jet boat, which means it can get into shallow waters to take readings and not worry about ripping a prop or high centering…both are not good ideas! I was out with Megan Palmer, Brie Welton, KC Longly and the other TAS Leyf Peirce. It was a cozy ride. There were a handful of targets that we set out to visually verify. The nice addition to this launch was that the computer had the updated LIDAR data from a fly over a few days earlier to use, so the launch did not have to take its own shoreline readings, cutting down on the time needed for the mission goals. There was one islet that was misplaced on the chart and so we had to take a picture of where it really was and then disprove its old location by taking depth readings and marking the bearing. This way the rock feature can be moved when the charts are updated.

There was also a shoal that was mis-assigned as to its depth. The LIDAR computers got a reading but were unsure and wanted field verification. We drove a star pattern over the shoal and logged readings, marked the area and took visual cues. Palmer will then work with the sheet and update from our field verifications and re-work the depths.

I was able to help run the logging computer. I marked the targets on the cue from the coxswain and then filled in the bearing, notes and depth or height of the target with the survey tech. I was also able to take digital pictures of some of the targets that we wanted to disprove or assign different locations.

Personal Log

Shoreline was much faster paced because the coxswain has to look out for kelp, watch his depth meter, and stay on target and read bearings/heading and depths to the survey tech. The launch itself is much more maneuverable because of the jet and has more room on deck to move around. Both of the TAS’s were on board this launch today so we were able to talk a little more about our plans for using the science we have learned and linking our classrooms in the future for some investigations.

We are pulling up the anchor and steaming for Kodiak this evening after dinner to arrive early on Friday morning. I am going to miss the crew on aboard. I feel that I have been here long enough to begin really getting to know people and they have added me into their daily schedules and have been patient with my questions or my getting in the way. I feel very safe and know that there are people who are looking out for me. I hope to keep in contact with some of the people on-board and maybe have them become part of my classroom as a resident scientist for the kids to interact with over the course of a season. The possibilities are endless.

Question of the Day:

Can the cartographers change locations of rocks when they make the final charts?

It all depends on the scale of the chart. If the chart is a small scale the cartographer might not worry about the exact location of rocks and might add in that there is a “rocky area”. If the chart is more specific to this area, the exact locations of rocks, shoals and other hazards are important.

Kirk Beckendorf, July 9, 2004

NOAA Teacher at Sea
Kirk Beckendorf
Onboard NOAA Ship Ronald H. Brown

July 4 – 23, 2004

Mission: New England Air Quality Study (NEAQS)
Geographical Area:
Northwest Atlantic Ocean
Date:
July 9, 2004

Weather Data from the Bridge
Time 8:00AM ET
Latitude- 43 43.31N
Longitude- 66 15.13 W
Air Temperature 11 C
Air Pressure 1010 Millibars
Wind Direction at surface SE
Wind Speed at surface <5 MPH
Wind Direction at 1 Kilometer- E
Wind Speed at 1 Kilometer <5 MPH
Wind Direction at 2 Kilometers E
Wind Speed at 2 Kilometer <5 MPH
Cloud cover and type Fog

Daily Log

One of the blind men observed an elephant and said it is like a tree, another said it was like a rope, another said it is like a water hose. Which was correct?

This morning I visited with Christoph Senff and Rich Marchbanks. After lunch I visited with Alan Brewer. All three are here from NOAA’s Environmental Technology Lab in Boulder, Colorado. Chris and Rich are operating a LIDAR, which remotely measures amount of ozone in the atmosphere. Alan has a Doppler LIDAR which remotely measures wind speed and direction. By “remotely,” that means they can measure ozone and wind from 3-4 kilometers away. An amazing thing about many of the instruments on board is that they have been designed and built by the scientists themselves. They can’t just run down to some high-tech store and buy their equipment, what they need isn’t for sale anywhere. They decide what needs to be done, and then they design and build the equipment that will do the job. The LIDARS that are being used here on the BROWN and in the rest of NEAQS project are examples of some of that “homemade” equipment.

In the case here on the ship “homemade” certainly does not mean it is just thrown together, held up with bubble gum, baling wire and duct tape. The LIDARS and the other instruments on board are extremely intricate, sophisticated and complicated devices.

To understand the very basics of how a LIDAR can detect ozone and air movement forget about LIDARS and just think about a normal flashlight. Pretend that you go outside in the middle of a completely dark night, no light from anywhere. Point your flashlight straight up and turn it on. Now imagine that there are a flock of white pigeons circling overhead, you will not see them unless the light from your flashlight hits them and then bounces back into your eye (hopefully it’s just the light that gets in your eye).

Now imagine that several of the pigeons poop and their poop is completely black and is between you and the pigeon. Yeah I know pigeon poop is usually white but for now pretend it is black. Because the poop is completely black when your beam of light hits the poop the light will not bounce off, instead it will be absorbed by the poop. The more poop in the air the more of the light is absorbed and less light bounces back to your eye.

Picture this. You are standing in the dark with your flashlight. The pigeons are circling over your head- between you and them is their poop. Quickly turn your flashlight on and then back off and measure the amount the amount of light that leaves. The light shoots up through the poop (which absorbs some of the light) and hits the pigeons. Some light bounces off the pigeons back through the poop and to your eye. You measure the light that comes back. By figuring out how much light was absorbed by the poop you can get an idea of how much is in the air above you.

Instead of visible light other wavelengths of light, like ultraviolet (UV) and infrared (IR), are used. Christoph, Rich and Alan use a laser rather than a flashlight and their LIDARs can turn the light on and off in nanoseconds. They can also measure many things about the light that leaves the laser and the light that returns.

Let’s take this one step further. Imagine that flashlight, dark night and poop and pigeons over head again. Also imagine that you can measure how long it takes for the beam of light to go out to some pigeons and then bounce back to your eye. If you know how fast the light is going you could calculate how far away they are and where the poop is located. If we put this all together and measure both how much light bounces back and how much time the light has traveled, you could determine the amount of poop at different distances.

Enough pretending and imagining, lets get back to the LIDARs. Light travels approximately 186,000 miles every second (it is about 25,000 miles around the equator) and the LIDARS can measure the time it takes the light to travel just a few hundred yards. Rich and Christoph’s ozone LIDAR is sensitive enough to measure ozone in parts per billion from 2-3 kilometers away and Alan’s LIDAR can measure wind speed and direction 3-4 kilometers away from here. They do this using a principal similar to the flashlight example, but obviously much more complicated. Chris and Rich’s ozone LIDAR uses a UV laser, picked specifically because its light will bounce off particles in the air (the pigeons) and be absorbed by ozone molecules (the pigeon poop). Allan uses an infrared laser that will bounce off particles floating and moving with the air. The particles, which are much too small to be seen would, as Allan said, seem like boulders to the beam of light.

What that all means, is that for the next six weeks along the ship’s path, the LIDAR’s will be measuring the amount of ozone pollution in the atmosphere, the wind speed and the wind direction.

The ozone LIDAR’s will eventually be used to show the amount and location of ozone pollution in the atmosphere from about 50 meters above the ocean surface up to 2-3 kilometers. The Doppler LIDAR data will be used to make a similar map of the wind speed and direction during the 6 weeks at sea. Eventually these and other data can be merged and compared.

What about those blind men examining the elephant? The first had grabbed the leg, the second had grabbed the tail and the third had grabbed the trunk. None of them of course had a complete picture of the elephant. During NEAQS-ITCT, hundreds of people are examining an elephant this summer. Individually they cannot give us a clear picture of the elephant. The elephant is air pollution. The more parts that can be accurately examined the better the picture. Instead of a trunk, tail and leg to observe, the scientist are examining the many kinds of chemicals in the pollution, the particles in the air, the movement of the pollution and the movement of the air. Different methods can be used to insure accuracy. Once each part of the elephant has been thoroughly examined and understood and all of the blind men evaluate their observations maybe they will have at least a partial picture of the elephant.

Question of the Day

What does LIDAR stand for?

How much of a second is a nanosecond?

Jane Temoshok, October 16, 2001

NOAA Teacher at Sea
Jane Temoshok
Onboard NOAA Ship Ronald H. Brown
October 2 – 24, 2001

Mission: Eastern Pacific Investigation of Climate Processes
Geographical Area: Eastern Pacific
Date: October 16, 2001

Latitude: 20º S
Longitude: 85º W
Air Temp. 19.8º C
Sea Temp. 18.6º C
Sea Wave: 1 – 2 ft.
Swell Wave: 3 – 4 ft.
Visibility: 8 – 10 miles
Cloud cover: 6/8

Science Log

LIDAR – Brandi McCarty & Scott Sandberg, ETL

Light and sound. LIDAR and RADAR. Both of these are used by scientists to observe the world. RADAR uses radio waves and LIDAR uses light waves. In this case, Brandi and Scott, from ETL in Colorado, use light waves, rather than sound waves, to observe clouds. They have a fully equipped van that was placed on the deck of the BROWN back in Seattle. Their major interest is observing the water vapor and wind velocity below and within stratus clouds. The instruments measure from 300 meters off the surface of the ocean up to about 4000 meters in the atmosphere.

Clouds have different functions. Depending upon how far they are away from the surface and what they are made from, clouds can act as a barrier to heat energy from the sun or as a blanket to keep heat trapped below.

Think of being in a hot desert. You would probably put on a light cloth to keep the burning sun out and keep you cooler. When the temperature drops though, you would want that cloth to keep your body heat in and not let it escape. Clouds are a lot like that. Mother Nature does a good job of keeping the planet at the right temperature. Now scientists want to figure out how she does it.

Brandi and Scott are working to collect lots of data that other scientists will use to make weather predictions. You can imagine that all the data that the ETL groups pull together from this trip could provide atmospheric scientists with lots of information to keep them busy for a long time.

Travel Log

R&R on NOAA Ship BROWN

In the evenings many of the scientific members as well as crew members enjoy playing games or cards, reading, or doing needlepoint. However the primary form of entertainment on the BROWN is watching videos. There is a big screen TV in the lounge. Crew member Mike puts out a schedule for the week of the videos that will be shown each night so you can plan ahead. He has hundreds and hundreds to choose from! Crew member Dave opens the ship store for us to buy popcorn or candy. The profits made at the store help to purchase new videos.

Temoshok 10-16-01 tvlounge
Scientists and crew members relax in the BROWN’s TV lounge.

Question of the day: Why is it important for all the “portholes” (windows) on the ship to be covered during the night?

Keep in touch,
Jane